





最新发布第21页
排序
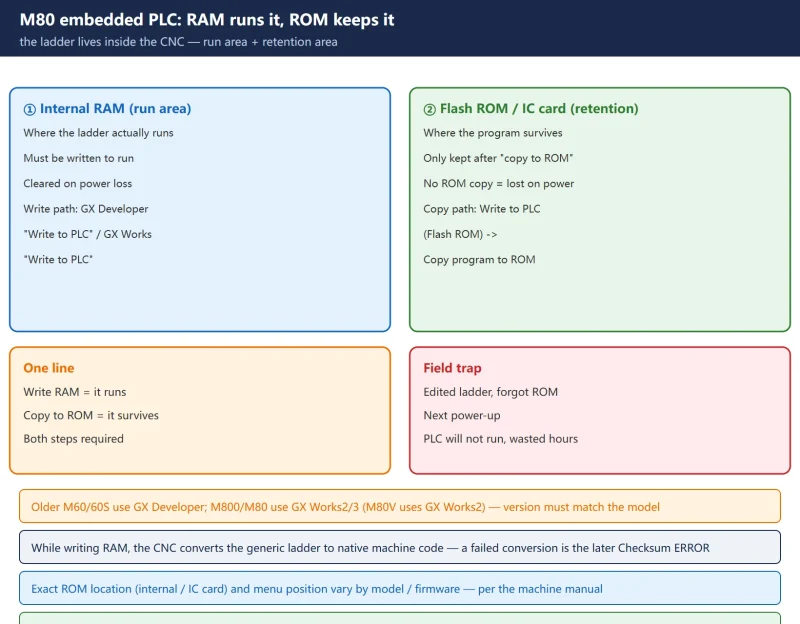
How to Write Mitsubishi M80 Ladder Logic into the CNC — RAM Write, ROM Copy and Checksum ERROR
How to write the Mitsubishi M80 / M800 ladder logic (the embedded PLC sequence program) into the CNC — the GX Developer / GX Works2·3 RAM write flow, why you must 'copy to ROM', ...

 前天
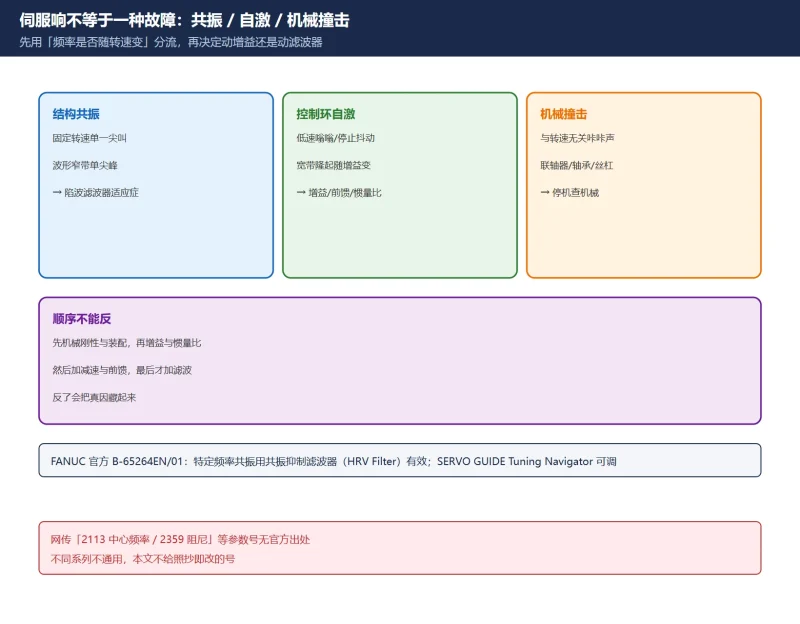
FANUC 伺服共振 / 啸叫怎么抑制?陷波滤波器(频率·带宽·衰减)参数设定 + Servo Guide 扫频定位全流程
伺服啸叫不是把增益调小一句话能解决的。本文按 FANUC 官方伺服调整手册与 HRV 滤波器通知,讲清共振、啸叫与机械撞击的分流、Servo Guide 扫频读尖峰频率、陷波滤波器三要素与多组分配,以及先...
6天前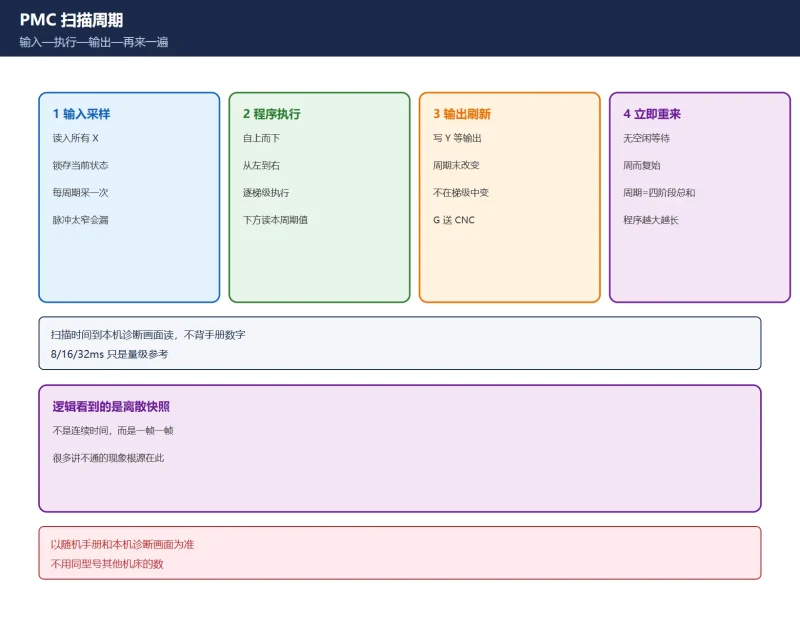
FANUC PMC 扫描周期怎么导致信号漏采、定时器提前:中文现场排查
按钮按了有时没反应、接近开关到位触点偶尔不亮、定时器没到时间就动作——这类偶发问题多半与 PMC 扫描周期有关。本页讲清输入—执行—输出四阶段、扫描时间以本机诊断画面为准、四类典型现象...
4天前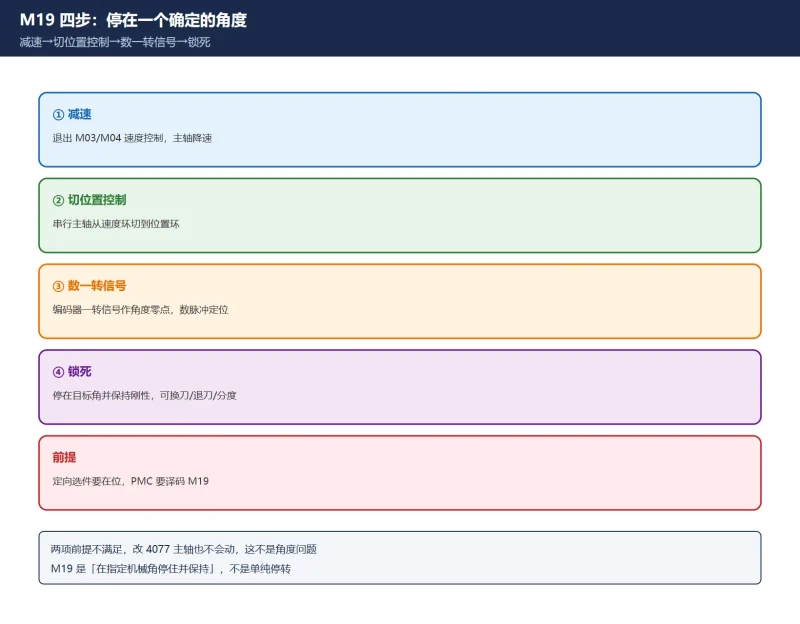
FANUC 主轴定向 M19 角度怎么调?参数 4077 换算公式(4096 脉冲/圈)+ 3117#1 与诊断 445/449 实操
M19 角度不对改的是 4077,但它存的是相对一转信号的偏移计数不是角度。本页给出换算式(4096 脉冲/圈、0.0879°/格、0–4095)、角度对照、3117#1 打开诊断 445/449 的标准调整路径,以及 G10 ...
5天前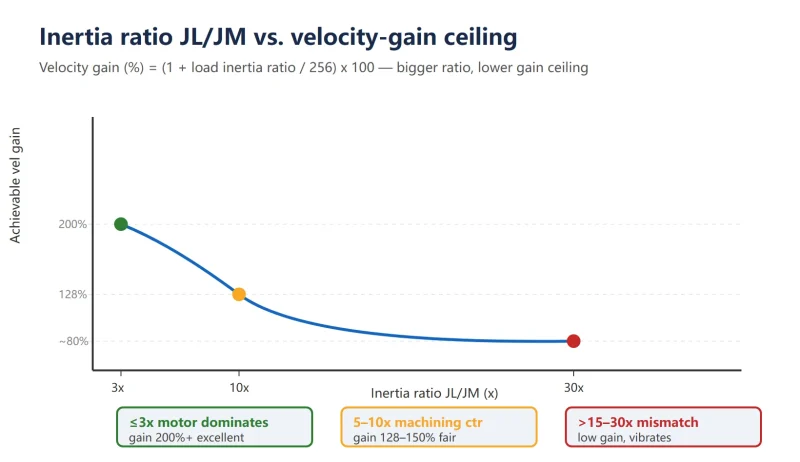
FANUC Inertia Ratio: Hand Calculation, Parameter 2021, Servo Guide and AI Servo Tuning
How to calculate and measure FANUC inertia ratio: hand formulas J=Mr² and J=M(P/2π)², parameter 2021 (default 128) and the velocity-gain conversion, Servo Guide / AI Servo Tunin...
昨天
SINUMERIK 828D After a Servo-Motor / Encoder Swap: MD34210 State Machine, MD34090 Offset, Three-Phase Referencing
After swapping a servo motor or encoder on an 828D, the axis often comes up with alarm 25022 'Axis Encoder Warning 0' or demands referencing again. What was lost is the corresponde...
21天前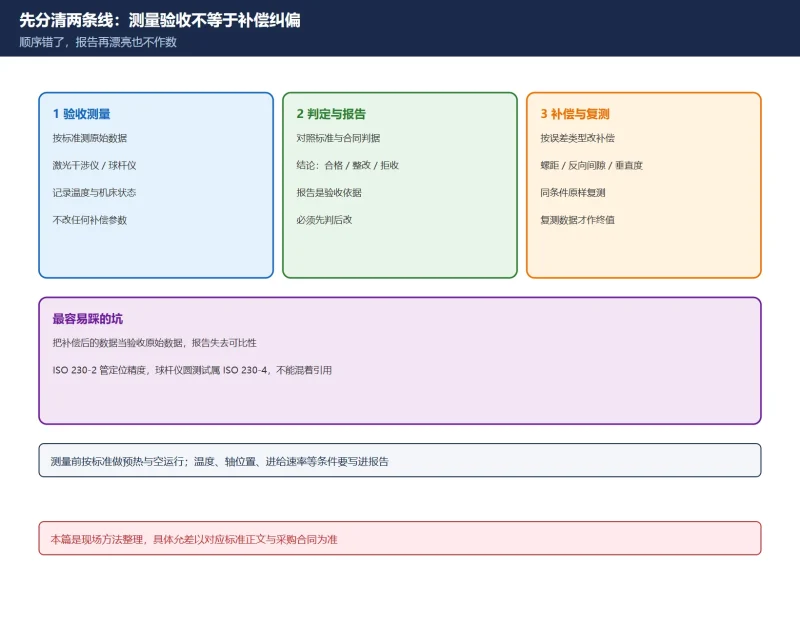
机床精度检验怎么做?球杆仪 ISO 230-4 与激光 ISO 230-2 判据对照
球杆仪做的是圆测试(ISO 230-4),激光干涉仪做的是定位精度与重复定位(ISO 230-2 / GB-T 17421.2),两者不是一套判据。本文给出标准分工、球杆仪六步作业、官方七类误差诊断项与验收结论三...
昨天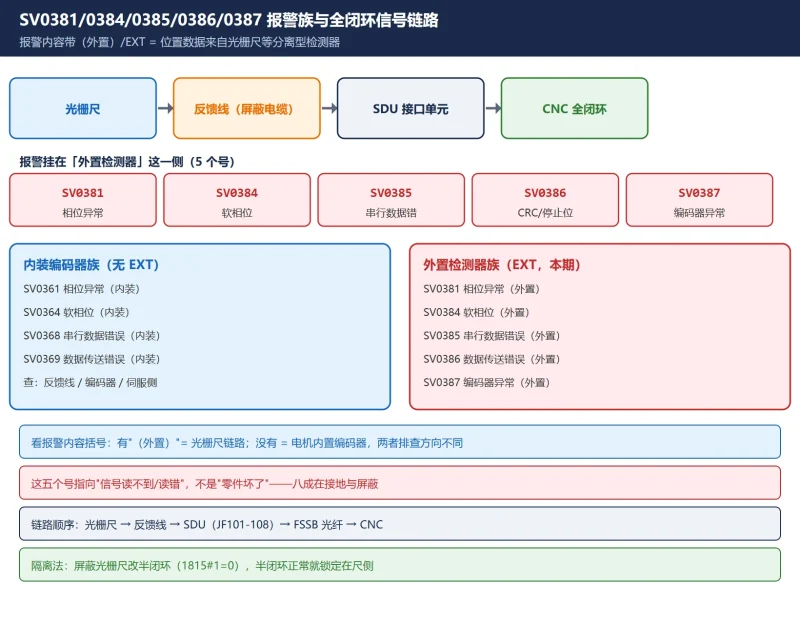
FANUC 光栅尺报警族 SV0381/0384/0385/0386/0387:接地不良引发的全闭环外置检测器故障排查
全闭环机床上 SV0381/0384/0385/0386/0387 常交替或反复跳,容易误判成光栅尺或放大器坏了。这一族报警内容都带'(外置)',指向光栅尺等分离型检测器的反馈链路,最常见根因是接地与屏蔽没做好...
前天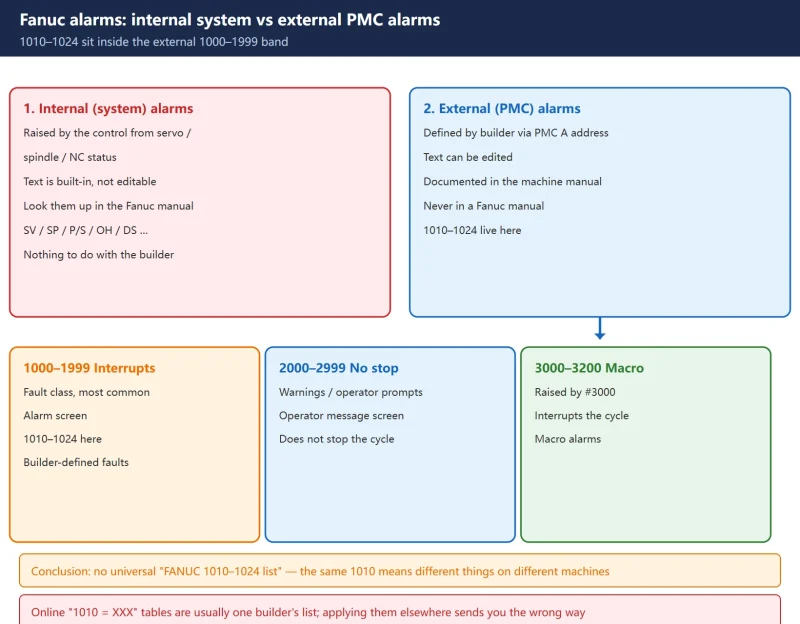
FANUC ATC Alarms 1010–1024 — Why They Are Not in the Fanuc Manual, and How to Trace Them
Why tool changer / ATC alarms 1010–1024 cannot be found in any Fanuc manual: they are machine-tool-builder external alarms driven by PMC A addresses. This guide covers the alarm n...
5天前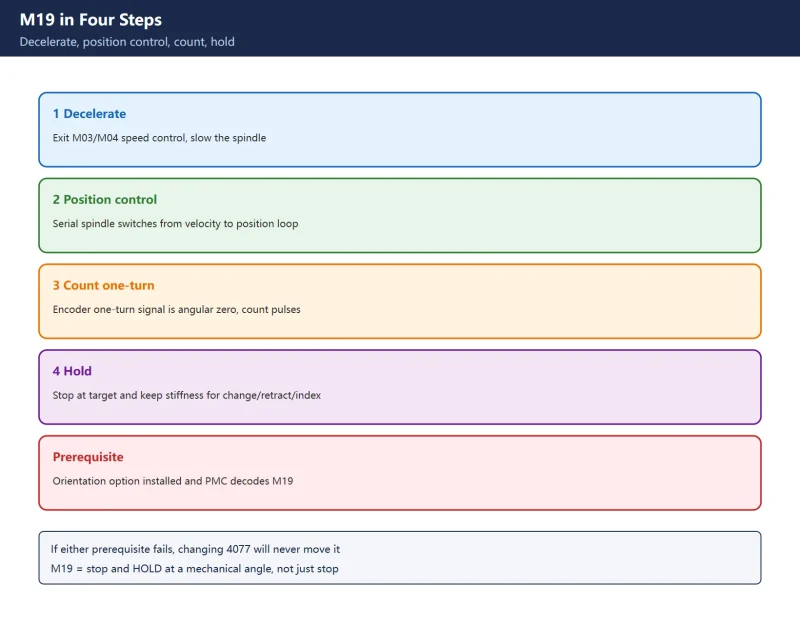
Fanuc M19 Spindle Orientation: Parameter 4077 Angle Formula, 3117#1 and Diagnostics 445/449
When M19 stops at the wrong angle, the value to change is 4077 - but it holds an offset count relative to the one-turn signal, not degrees. Verified formula (4096 counts/rev, 0.087...
5天前






扫一扫,添加我的微信










