

 cncshare

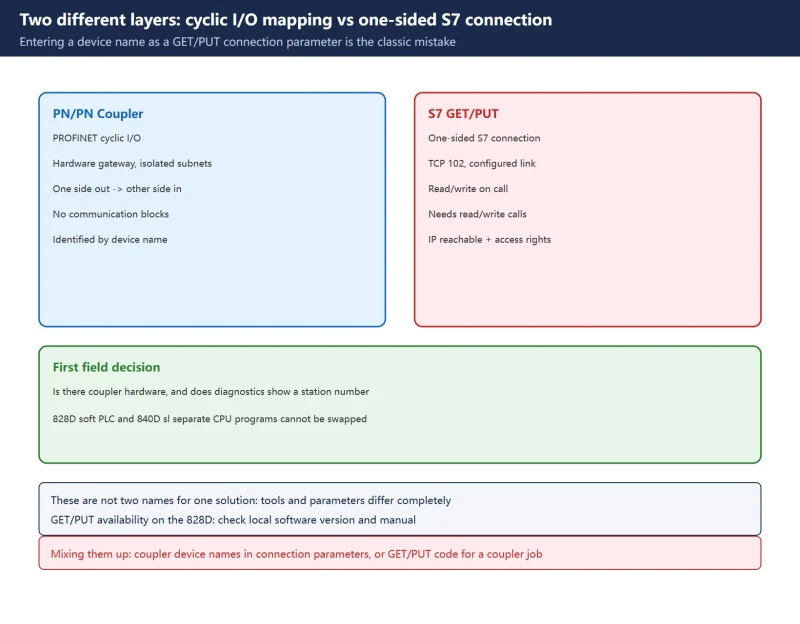
SINUMERIK 828D to S7-1200/1500: PN/PN Coupler Cyclic I/O vs S7 GET/PUT
A PN/PN Coupler exchanges data through PROFINET cyclic I/O mapping; S7 GET/PUT uses a one-sided S7 connection. Official configuration order, X1/X2 network split, MD12986, byte-exte...
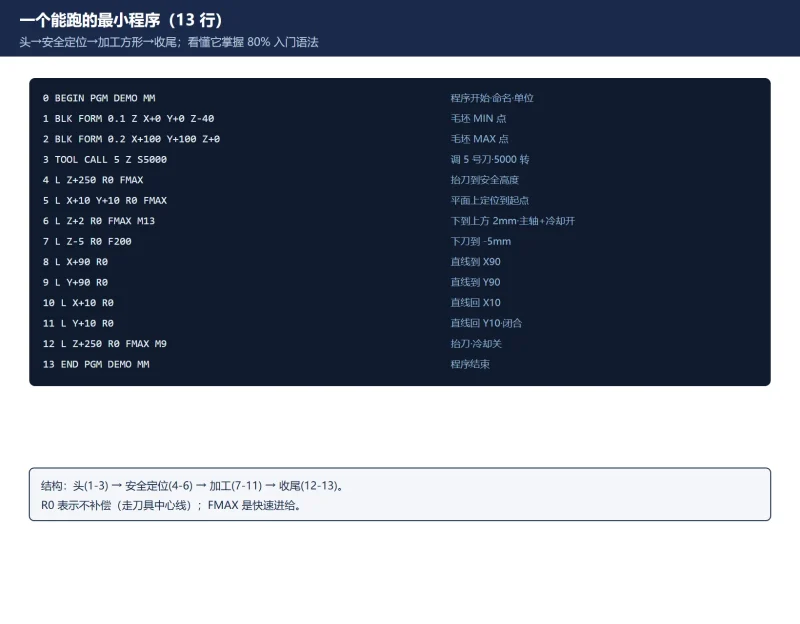
海德汉 TNC 对话式编程入门:一个最小程序看懂 BEGIN/BLK FORM/TOOL CALL/L/C/CR/APPR/循环
海德汉 Klartext 对话式编程,屏幕问一句你答一句,不用背 G 代码。本文用一个 13 行能跑的最小程序,逐行讲清 BEGIN PGM、BLK FORM 毛坯、TOOL CALL 刀具、L 直线、C/CR 圆弧、R0/RL/RR 补偿、...
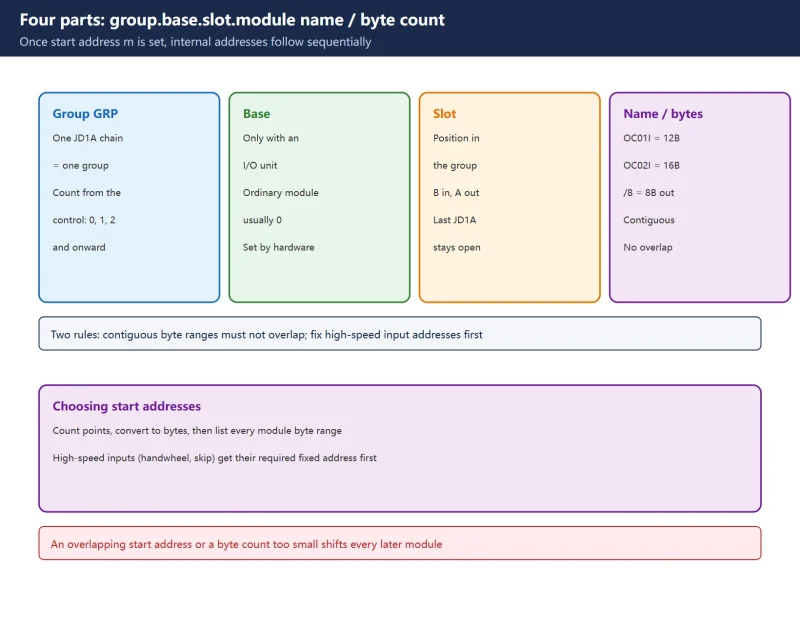
FANUC I/O Link Address Assignment: Group.Base.Slot, OC01I / OC02I and the 16-Byte Handwheel Rule
I/O Link address assignment is a four-part expression of group, base, slot and module byte count. Module byte counts, why a handwheel needs 16 bytes, I/O Link vs I/O Link i, and a ...
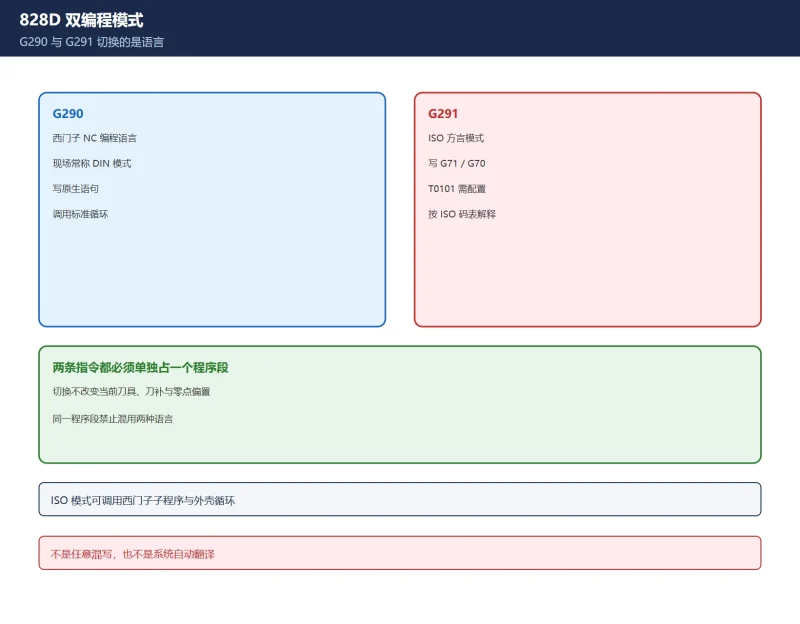
SINUMERIK 828D G290 G291 怎么切?DIN 写法与 ISO 写法逐行对照
G290 激活西门子 NC 编程语言,G291 激活 ISO 方言;两者必须单独成段,同段禁止混写。本页给出程序头、换刀、主轴、轮廓、循环的逐行对照,并用西门子官方手册纠正“模式可互相识别”的真正含...
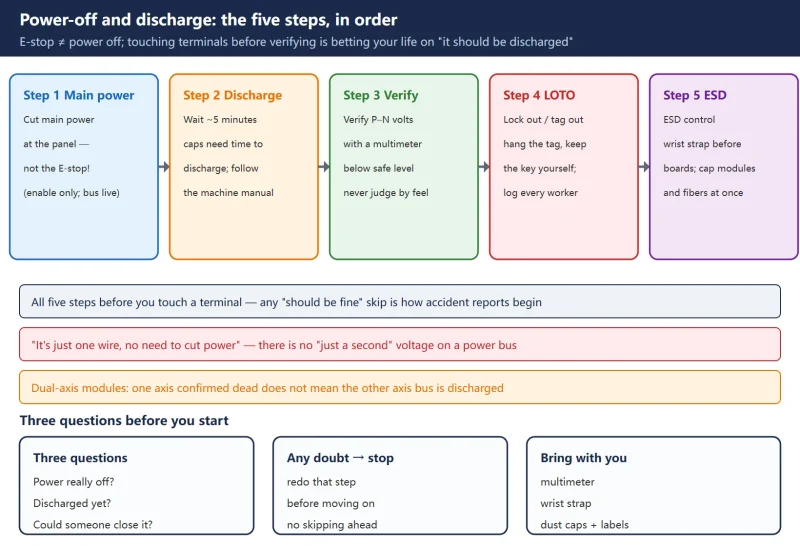
FANUC Servo Amplifier Replacement: Power-Off and Discharge, Teardown Order, Motor ID No.2020 Write-Back, Three Post-Swap Checks
A complete FANUC servo amplifier replacement procedure following official αi / βi parameter wording: the repair-or-replace decision, cutting main power (not the E-stop) and waiti...
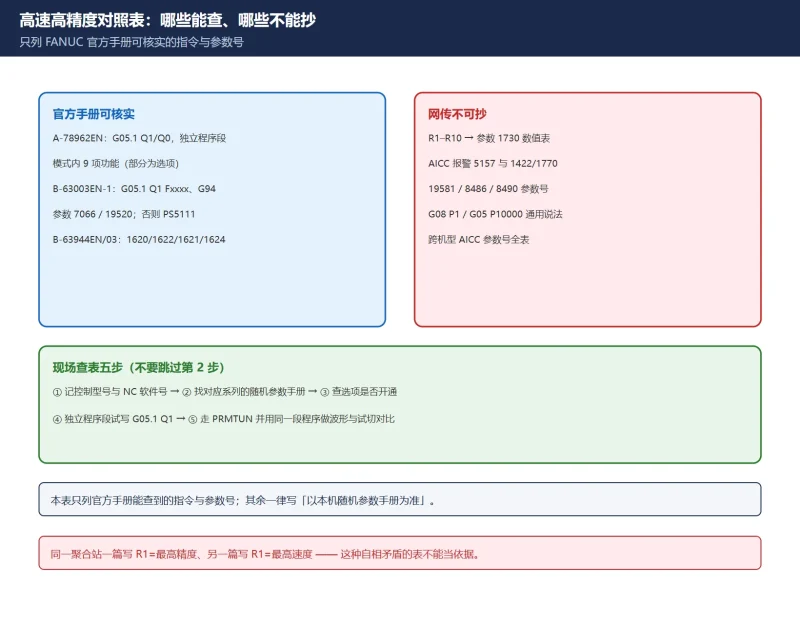
FANUC 高速高精度 / 平滑控制跨机型对照表:AICC、纳米平滑、G05.1 Q1 与官方手册可核实的参数
一页查清 AICC / AI 纳米轮廓控制的叫法、G05.1 Q1/Q0 指令格式、官方手册可核实的参数(7066、19520、1620/1622 等)与跨机型确认方法。网传的「AICC 参数号全表」来源互相矛盾,本表逐条标明...
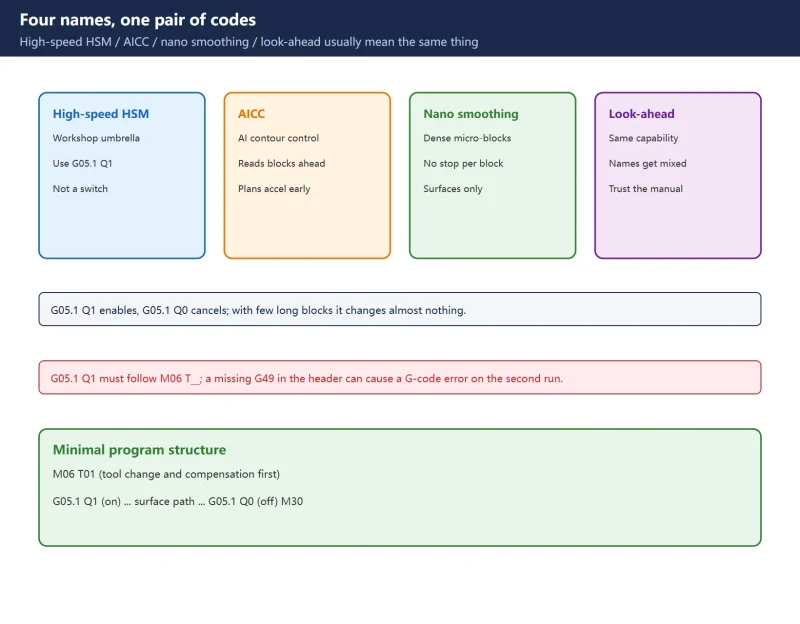
FANUC AICC / Nano Smoothing Setup: G05.1 Q1, Parameter-Side Enable, and Six Reasons It Does Nothing
G05.1 Q1 turns on high-speed high-precision contour control and Q0 cancels it, but the G-code alone is not enough. This guide covers the PRMTUN high-precision setup path, checking ...

FANUC 仿真软件怎么选?官方 CNC Guide 四件套、授权方式与「免费版」的合规边界
搜「FANUC 仿真软件下载」的人大多冲着「免费版」去,但 FANUC 官方仿真(CNC Guide)是带硬件密钥的授权产品;网传「官方仿真仅美洲提供」也是错的。本页把官方四件套的规格、两种硬件密钥、第...
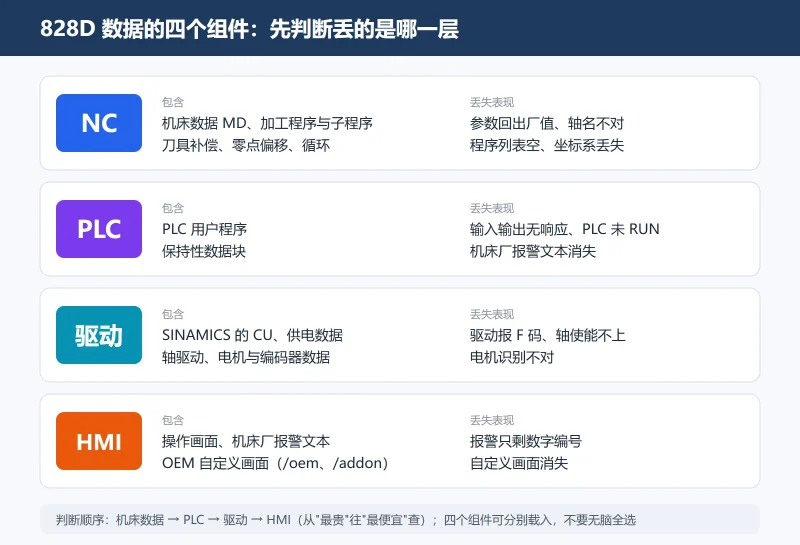
SINUMERIK 828D/802D 数据丢了还能救吗?程序/参数/PLC 三层恢复顺序与缺省模式启动操作详解
828D/802D 数据丢了怎么救:先判断丢的是 NC/PLC/驱动/HMI 哪一层,读懂 4062 与 4060 相反的含义,再按内部备份、.ard 存档、缺省模式启动三条路径恢复。含 SUNRISE 口令与轴名错位提醒。
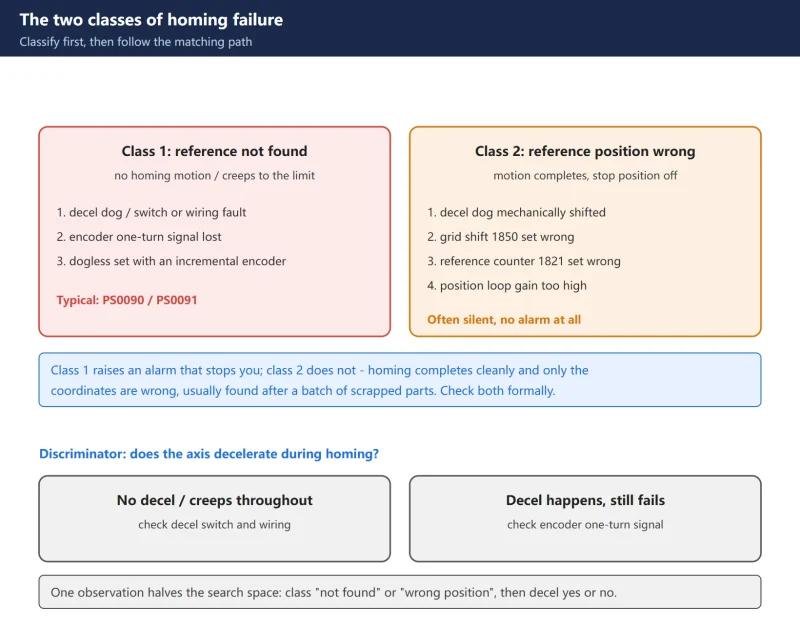
How to Classify and Troubleshoot CNC Homing Failures: Reference Not Found vs Wrong Reference Position + Decel Dog / One-Turn Signal + Grid Shift 1850 / Reference Counter 1821 + Absolute Encoder Battery
Stop swapping parts to see what sticks. Split homing failures into two classes: reference not found, and reference position wrong. In the first class, watch whether the axis decele...








